KI-Beratung Beta

Gutscheinbedingungen

**Gültig bis 11.11.2026 auf Spielzeug, Schreibwaren, Filme, Geschenke & Trends, Musik, tolino eReader & Zubehör, Hörbücher und Hörbuch-Downloads, nicht preisgebundene Bücher und Kalender online auf thaalia.live und in der Thalia App. Einzelne Artikel können ausgeschlossen sein. Aufgrund der Buchpreisbindung sind deutschsprachige Bücher und eBooks ausgenommen. Zusätzlich ausgenommen sind Abos & Flatrates, Games, Geschenkkarten/-boxen, Shelfies, Software, Zeitschriften sowie einzelne Artikel von tonies®. Pro Einkauf einmal einlösbar. Click & Collect nur bei Onlinevorabzahlung möglich. Keine Barauszahlung. Nicht kombinierbar mit anderen Aktionen und Gutscheinen. Gutschein wird auf max. 500€ Bestellwert angerechnet. Nicht gültig für Versandkosten und Services.

  • Produktbild: Biologically Inspired Robot Behavior Engineering
  • Produktbild: Biologically Inspired Robot Behavior Engineering
  • Produktbild: Biologically Inspired Robot Behavior Engineering
Band 109

Biologically Inspired Robot Behavior Engineering

164,99 €

inkl. gesetzl. MwSt., Versandkostenfrei


Beschreibung

The book presents an overview of current research on biologically inspired autonomous robotics from the perspective of some of the most relevant researchers in this area. The book crosses several boundaries in the field of robotics and the closely related field of artificial life. The key aim throughout...

Beschreibung

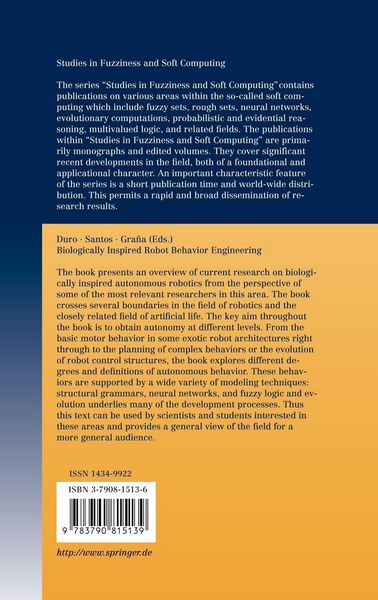
The book presents an overview of current research on biologically inspired autonomous robotics from the perspective of some of the most relevant researchers in this area. The book crosses several boundaries in the field of robotics and the closely related field of artificial life. The key aim throughout the book is to obtain autonomy at different levels. From the basic motor behavior in some exotic robot architectures right through to the planning of complex behaviors or the evolution of robot control structures, the book explores different degrees and definitions of autonomous behavior. These behaviors are supported by a wide variety of modeling techniques: structural grammars, neural networks, and fuzzy logic and evolution underlies many of the development processes. Thus this text can be used by scientists and students interested in these areas and provides a general view of the field for a more general audience.

Produktdetails

Einband

Gebundene Ausgabe

Erscheinungsdatum

22.10.2002

Abbildungen

XX, 439 p.

Herausgeber Richard J. Duro + weitere

Produktdetails

Einband

Gebundene Ausgabe

Erscheinungsdatum

22.10.2002

Abbildungen

XX, 439 p.

Herausgeber
Verlag Physica
Seitenzahl

439

Maße (L/B/H)

24,1/16/3 cm

Gewicht

800 g

Auflage

2003

Sprache

Englisch

ISBN

978-3-7908-1513-9

Herstelleradresse

Physica Verlag
Tiergartenstr. 17
69121 Heidelberg
DE

Email: ProductSafety@springernature.com

Noch keine Bewertungen vorhanden

Verfassen Sie die erste Bewertung zu diesem Artikel

Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.

Kundinnen und Kunden meinen

Bewertungen (0)

  • Produktbild: Biologically Inspired Robot Behavior Engineering
  • Produktbild: Biologically Inspired Robot Behavior Engineering
  • Produktbild: Biologically Inspired Robot Behavior Engineering
  • 1. Evolutionary approaches to neural control of rolling, walking, swimming and flying animats or robots.- 2. Behavior coordination and its modification on monkey-type mobile robot.- 3. Visuomotor control in flies and behavior-based agents.- 4. Using evolutionary methods to parameterize neural models: a study of the lamprey central pattern generator.- 5. Biologically inspired neural network approaches to real-time collision-free robot motion planning.- 6. Self-adapting neural networks for mobile robots.- 7. Evolving robots able to integrate sensory-motor information over time.- 8. A non-computationally-intensive neurocontroller for autonomous mobile robot navigation.- 9. Some approaches for reusing behaviour based robot cognitive architectures obtained through evolution.- 10. Modular neural architectures for robotics.- 11. Designing neural control architectures for an autonomous robot using vision to solve complex learning tasks.- 12. Robust estimation of the optical flow based on VQ-BF.- 13. Steps towards one-shot vision-based self-localization.- 14. Computing the optimal trajectory of arm movement: the TOPS (Task Optimization in the Presence of Signal-dependent noise) model.- 15. A general learning approach to visually guided 3D-positioning and pose control of robot arms.